nyu-advanced-mechatronics
Advanced Mechatronics — NYU
We built robots. Three of them, over one semester, each one smarter than the last.
Group 19: Dajr Alfred, Mohammed Nauman Shariff, Gordon Oboh
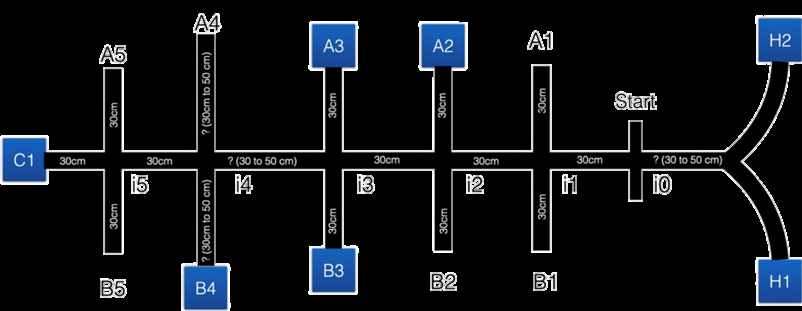
The track — a grid inspired by Manhattan and Brooklyn streets. The robot starts at H1 or H2 and navigates through intersections to deliver test kits, avoid obstacles, and identify friend or foe.
The Projects
1. The Arduino Robot
Our first robot. An Arduino Nano with an 8-sensor IR array to follow a black line, three ultrasonic sensors to detect objects, and a pair of servo motors for wheels. It navigates a parking-lot track, stops at intersections, and approaches detected objects within 7cm.
What it does: Follows a line, finds objects, stops in front of them.
Robot navigating the track and approaching an object
2. The Propeller Robot
Same task, smarter brain. We swapped the single-core Arduino for a Parallax Propeller with 8 parallel cores (COGs), using the Arduino as a sensor reader. Now the robot could follow the line, scan for obstacles, control its wheels, and flash indicators — all at the same time.
What’s new: Multi-core processing means it doesn’t have to stop and scan anymore. It can handle obstacle avoidance on a full grid track with 16 intersections and 10 delivery points.
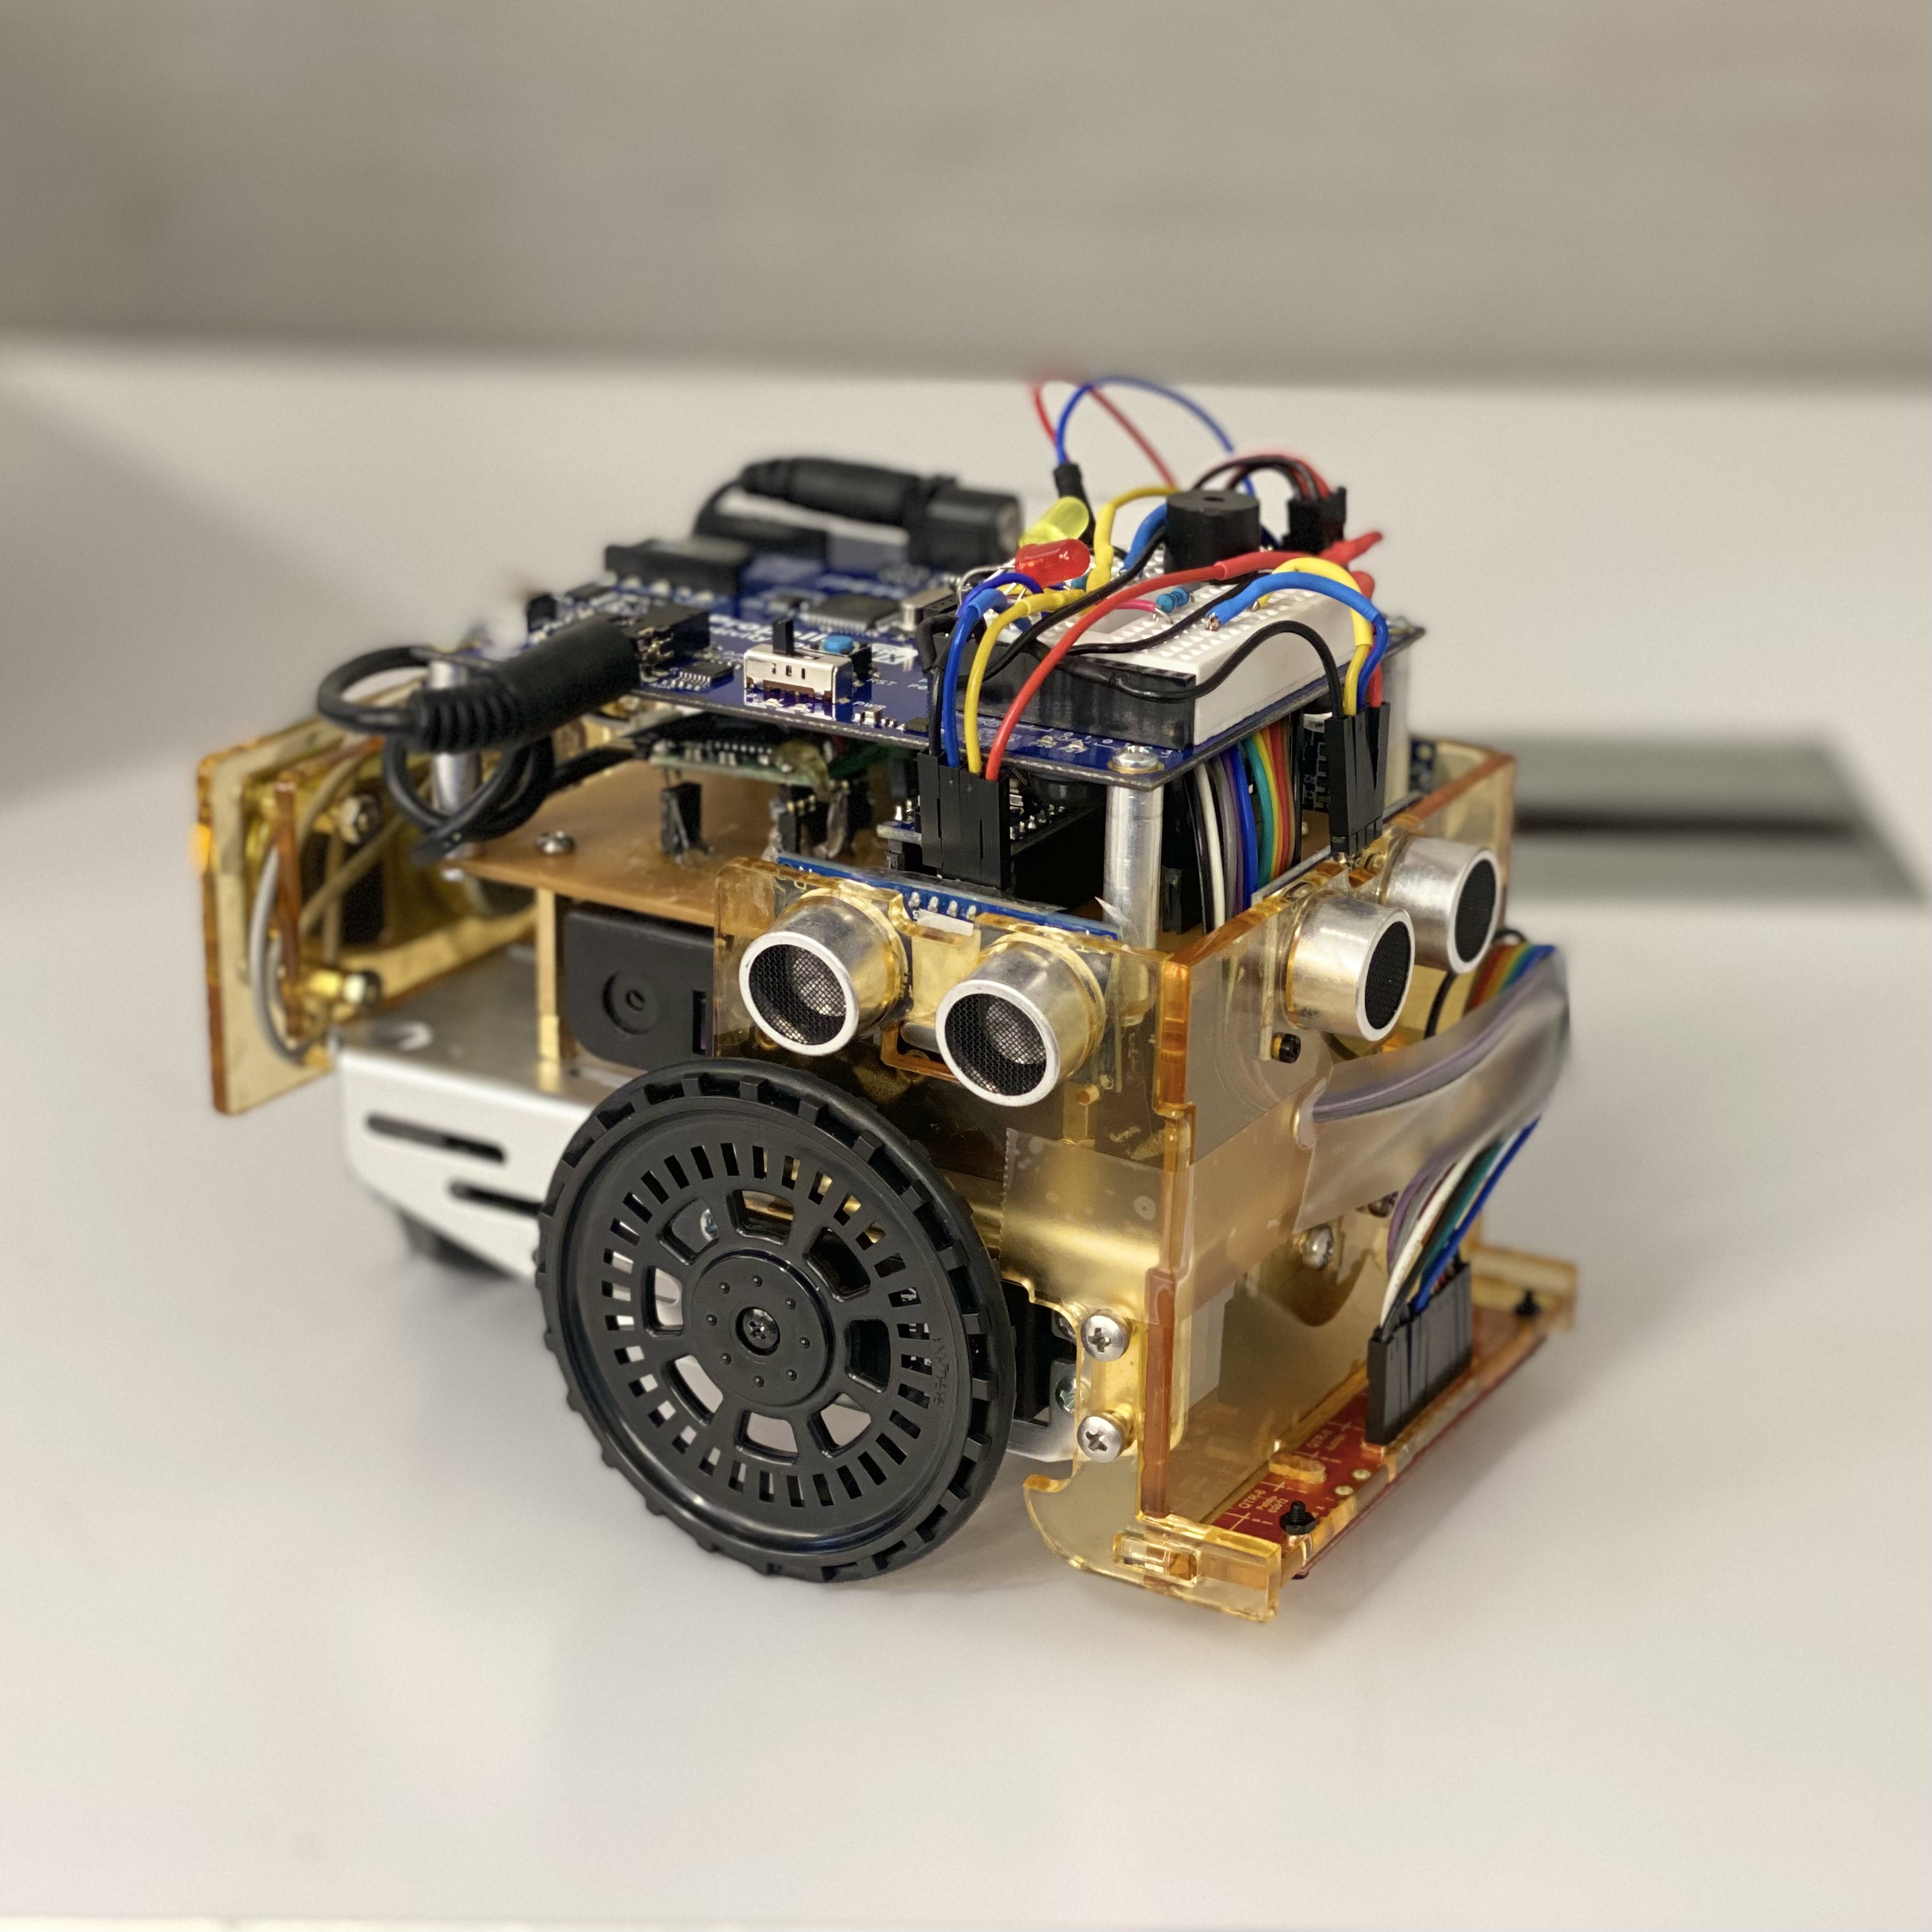
The Propeller robot with Arduino, QTR sensor, ultrasonic sensors, and servos
Robot navigating the grid track with obstacle avoidance
3. The Term Project — Friend or Foe?
This is where it gets fun. We added a Raspberry Pi with a camera to the Propeller + Arduino setup. Now the robot can see. It detects ArUco markers and decides if they’re a friend or an enemy.
- Friend (ID ≤ 9): “Hasta La Vista, Baby” plays. The robot leaves them alone.
- Foe (ID > 9): “MK.mp3” plays. The arm servo deploys.
Three processors, one robot, and a whole lot of personality.
Robot scanning for ArUco markers and identifying friend or foe
Hardware Evolution
| Component | Arduino Project | Propeller Project | Term Project |
|---|---|---|---|
| Arduino Nano | ✓ QTR reader + control | ✓ QTR reader only | ✓ QTR reader only |
| Propeller | — | ✓ Master controller | ✓ Master controller |
| Raspberry Pi 3B | — | — | ✓ Vision processing |
| Camera Module V2 | — | — | ✓ ArUco detection |
| Pololu QTR-8RC | ✓ | ✓ | ✓ |
| HC-SR04 / Ping | 3x | 3x | 3x |
| Servo motors | 2x drive | 2x drive | 2x drive + 1x arm |
| LEDs | Blue + Red | Blue + Red | Blue + Red |
| Buzzer | — | ✓ | ✓ |
Software Evolution
| Capability | Arduino | Propeller | Term |
|---|---|---|---|
| Line-following | ✓ | ✓ | ✓ |
| Intersection detection | ✓ | ✓ | ✓ |
| Ultrasonic object scan | ✓ | ✓ | ✓ |
| Multi-core parallelism | — | ✓ | ✓ |
| Obstacle avoidance | — | ✓ | ✓ |
| Grid track navigation | — | ✓ | ✓ |
| ArUco marker detection | — | — | ✓ |
| Friend/Foe classification | — | — | ✓ |
| Servo arm actuation | — | — | ✓ |
| Audio cues | — | — | ✓ |
What’s in the repo
| Folder | Contains |
|---|---|
Arduino Project/ |
Code, report, and demo video of the Arduino line-follower |
Propeller Project/ |
Propeller + Arduino code, report, demo, and robot photo |
Term Project/ |
Propeller + Arduino + RPi code, report, demo videos, audio files |