A new cohort, more gender-diverse, and a project that grew from simple lessons into a game designed by the scholars themselves.
flowchart LR
    subgraph W1["Warm-Up"]
        A[Pass the Brick<br/>collaborative activity] --> B[Show previous year's<br/>car & line follower]
    end

    subgraph W2["Skill Building"]
        B --> C[Training Camp 1:<br/>Driving Around]
    end

    subgraph W3["Final Project"]
        C --> D[Driving Base<br/>+ Gripper]
        D --> E[Scholar suggests<br/>making a game]
        E --> F["Scholars design<br/>rules & setup"]
    end
I started the scholars with a simple collaborative activity — Pass the Brick. No complex code, just teamwork and getting comfortable with the robots. They loved it.
Once they were comfortable, I showed them what the 2024-2025 cohort had built — the RC car and the line-following robot. They saw where this was headed and were eager to get there.
We worked through Training Camp 1 — Driving Around, a structured lesson on controlling a driving base. They picked it up fast, and I made sure to acknowledge every win — the first straight line, the first turn without crashing.
The final project: combining a driving base with a gripper. Not just moving, but interacting — grabbing, carrying, and manipulating objects.
DriveBase_1.pyXbox controller-controlled driving base with gripper, built with Pybricks.
Hardware setup:
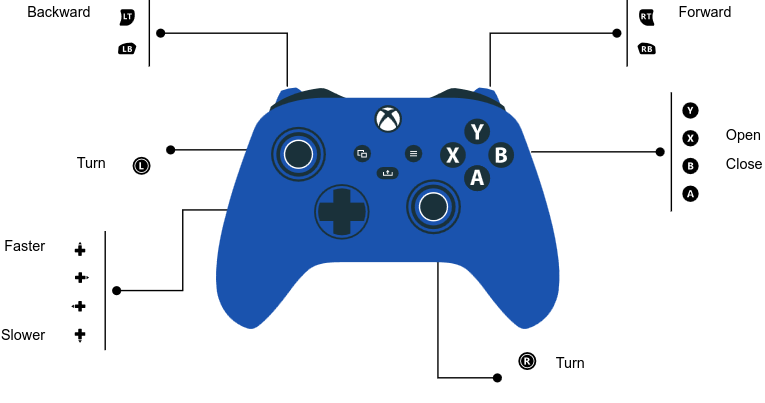
Xbox controller button layout
Control flow:
flowchart LR
    subgraph Input["Controller"]
        Triggers["Triggers L/R<br/>forward/reverse"]
        Joysticks["Joysticks L/R<br/>steering"]
        Buttons["A | B | X | Y<br/>DPad Up/Down"]
    end

    subgraph Logic["Logic"]
        Turbo["trim_or_turbo()<br/>A=100% | Y=25% | else=75%"]
        Trim["transmission_manual()<br/>DPad Up/Down adjusts<br/>speed trim (0-7)"]
        Gripper["gripper()<br/>B=close | X=open<br/>experimental: stall-detection"]
    end

    subgraph Output["Output"]
        Drive["DriveBase.drive()<br/>speed + steering"]
        Rumble["Controller.rumble()<br/>trigger feedback"]
        Display["Hub display<br/>shows trim level"]
    end

    Triggers --> Trim
    Joysticks --> Drive
    Buttons --> Turbo
    Buttons --> Gripper
    Turbo --> Drive
    Trim --> Drive
Features:
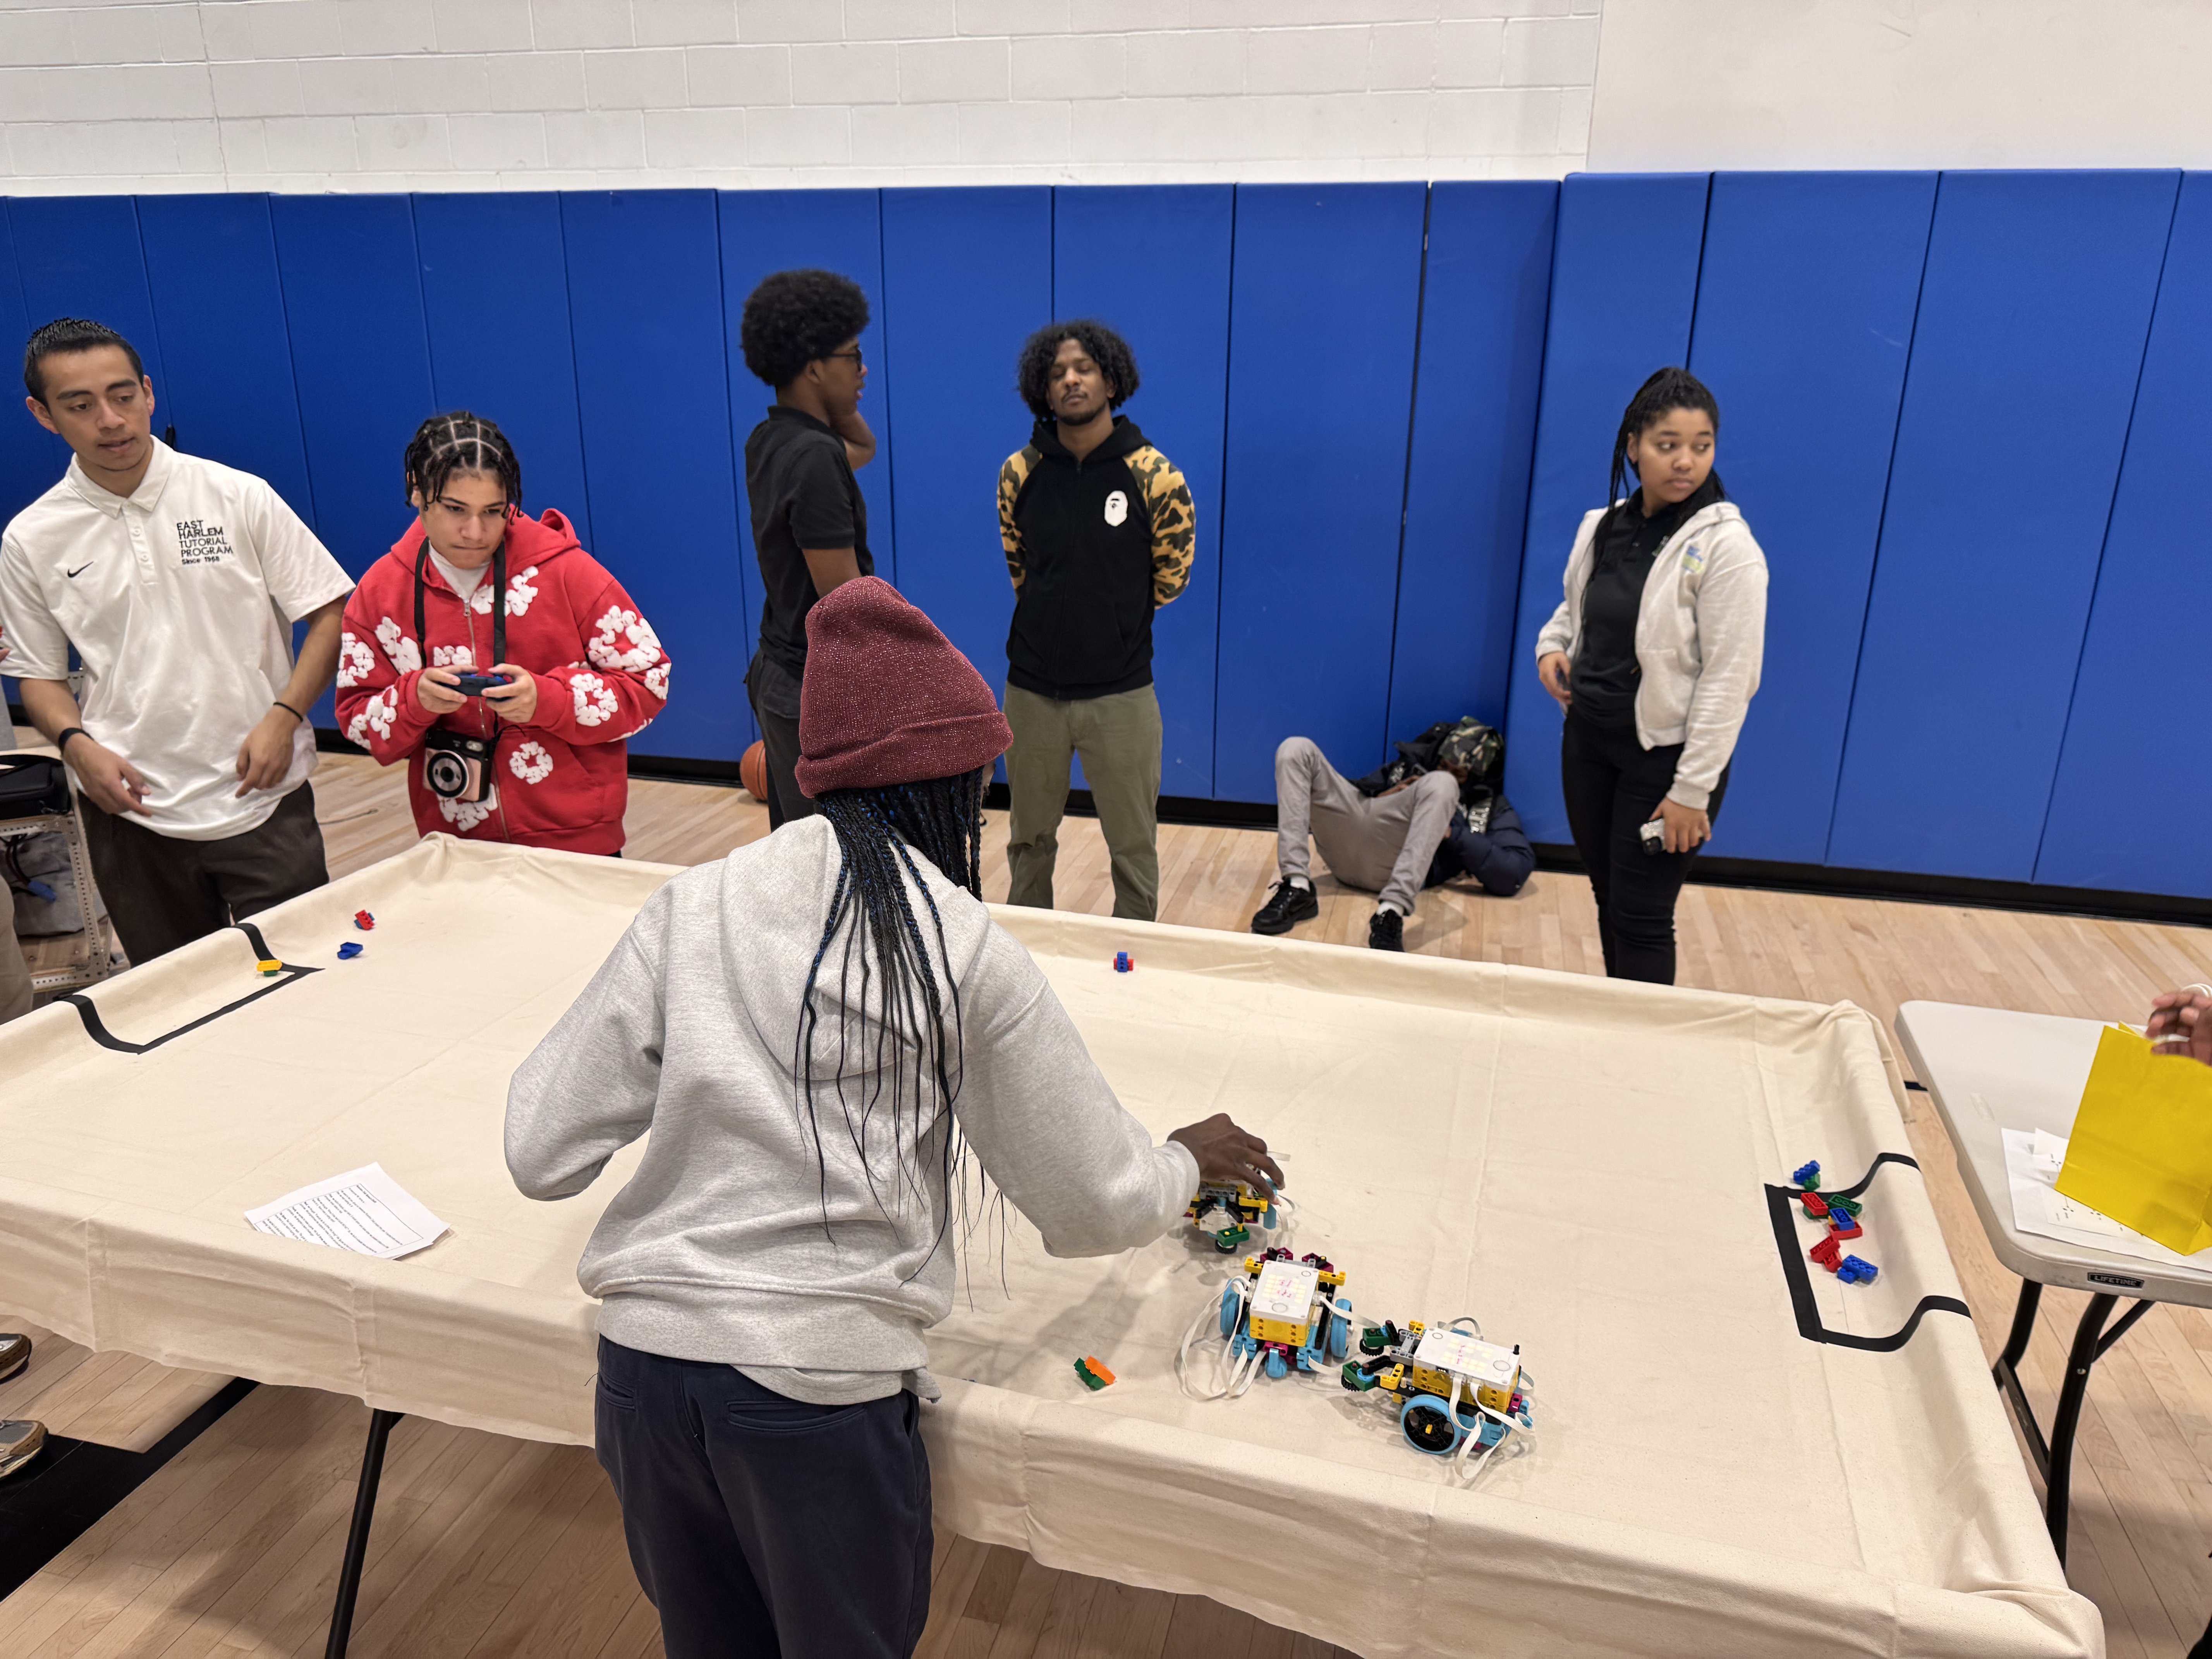
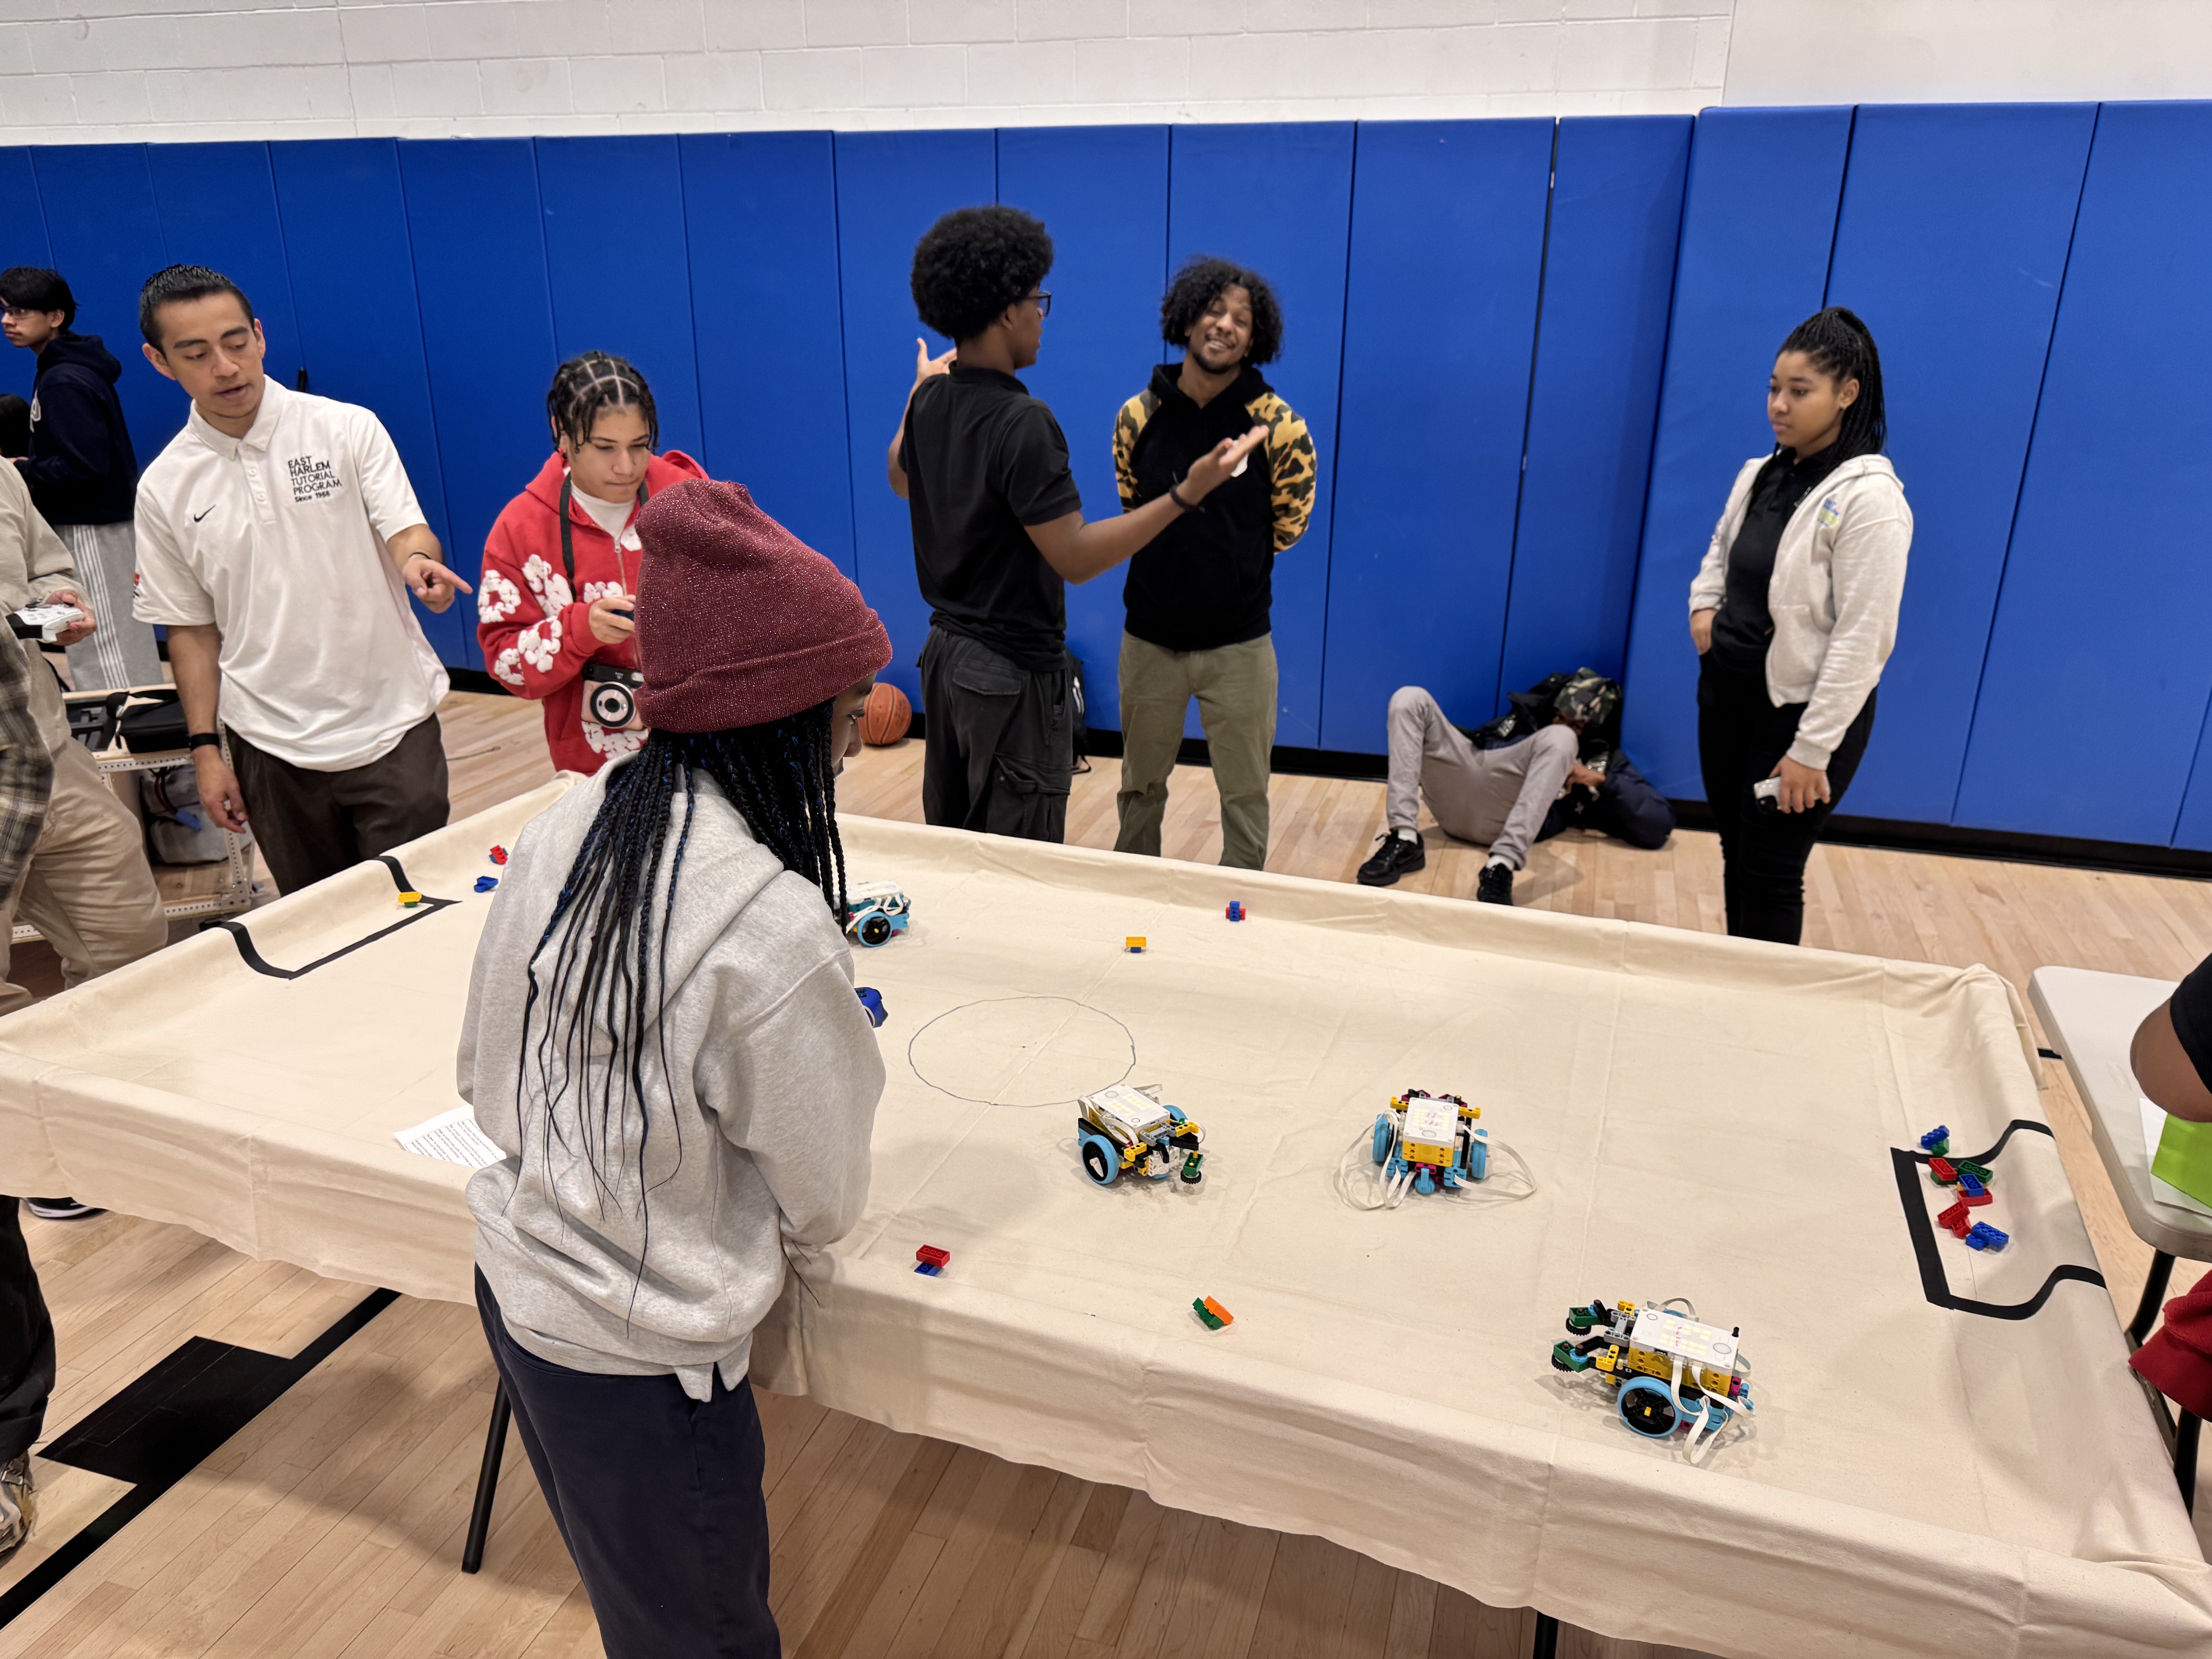
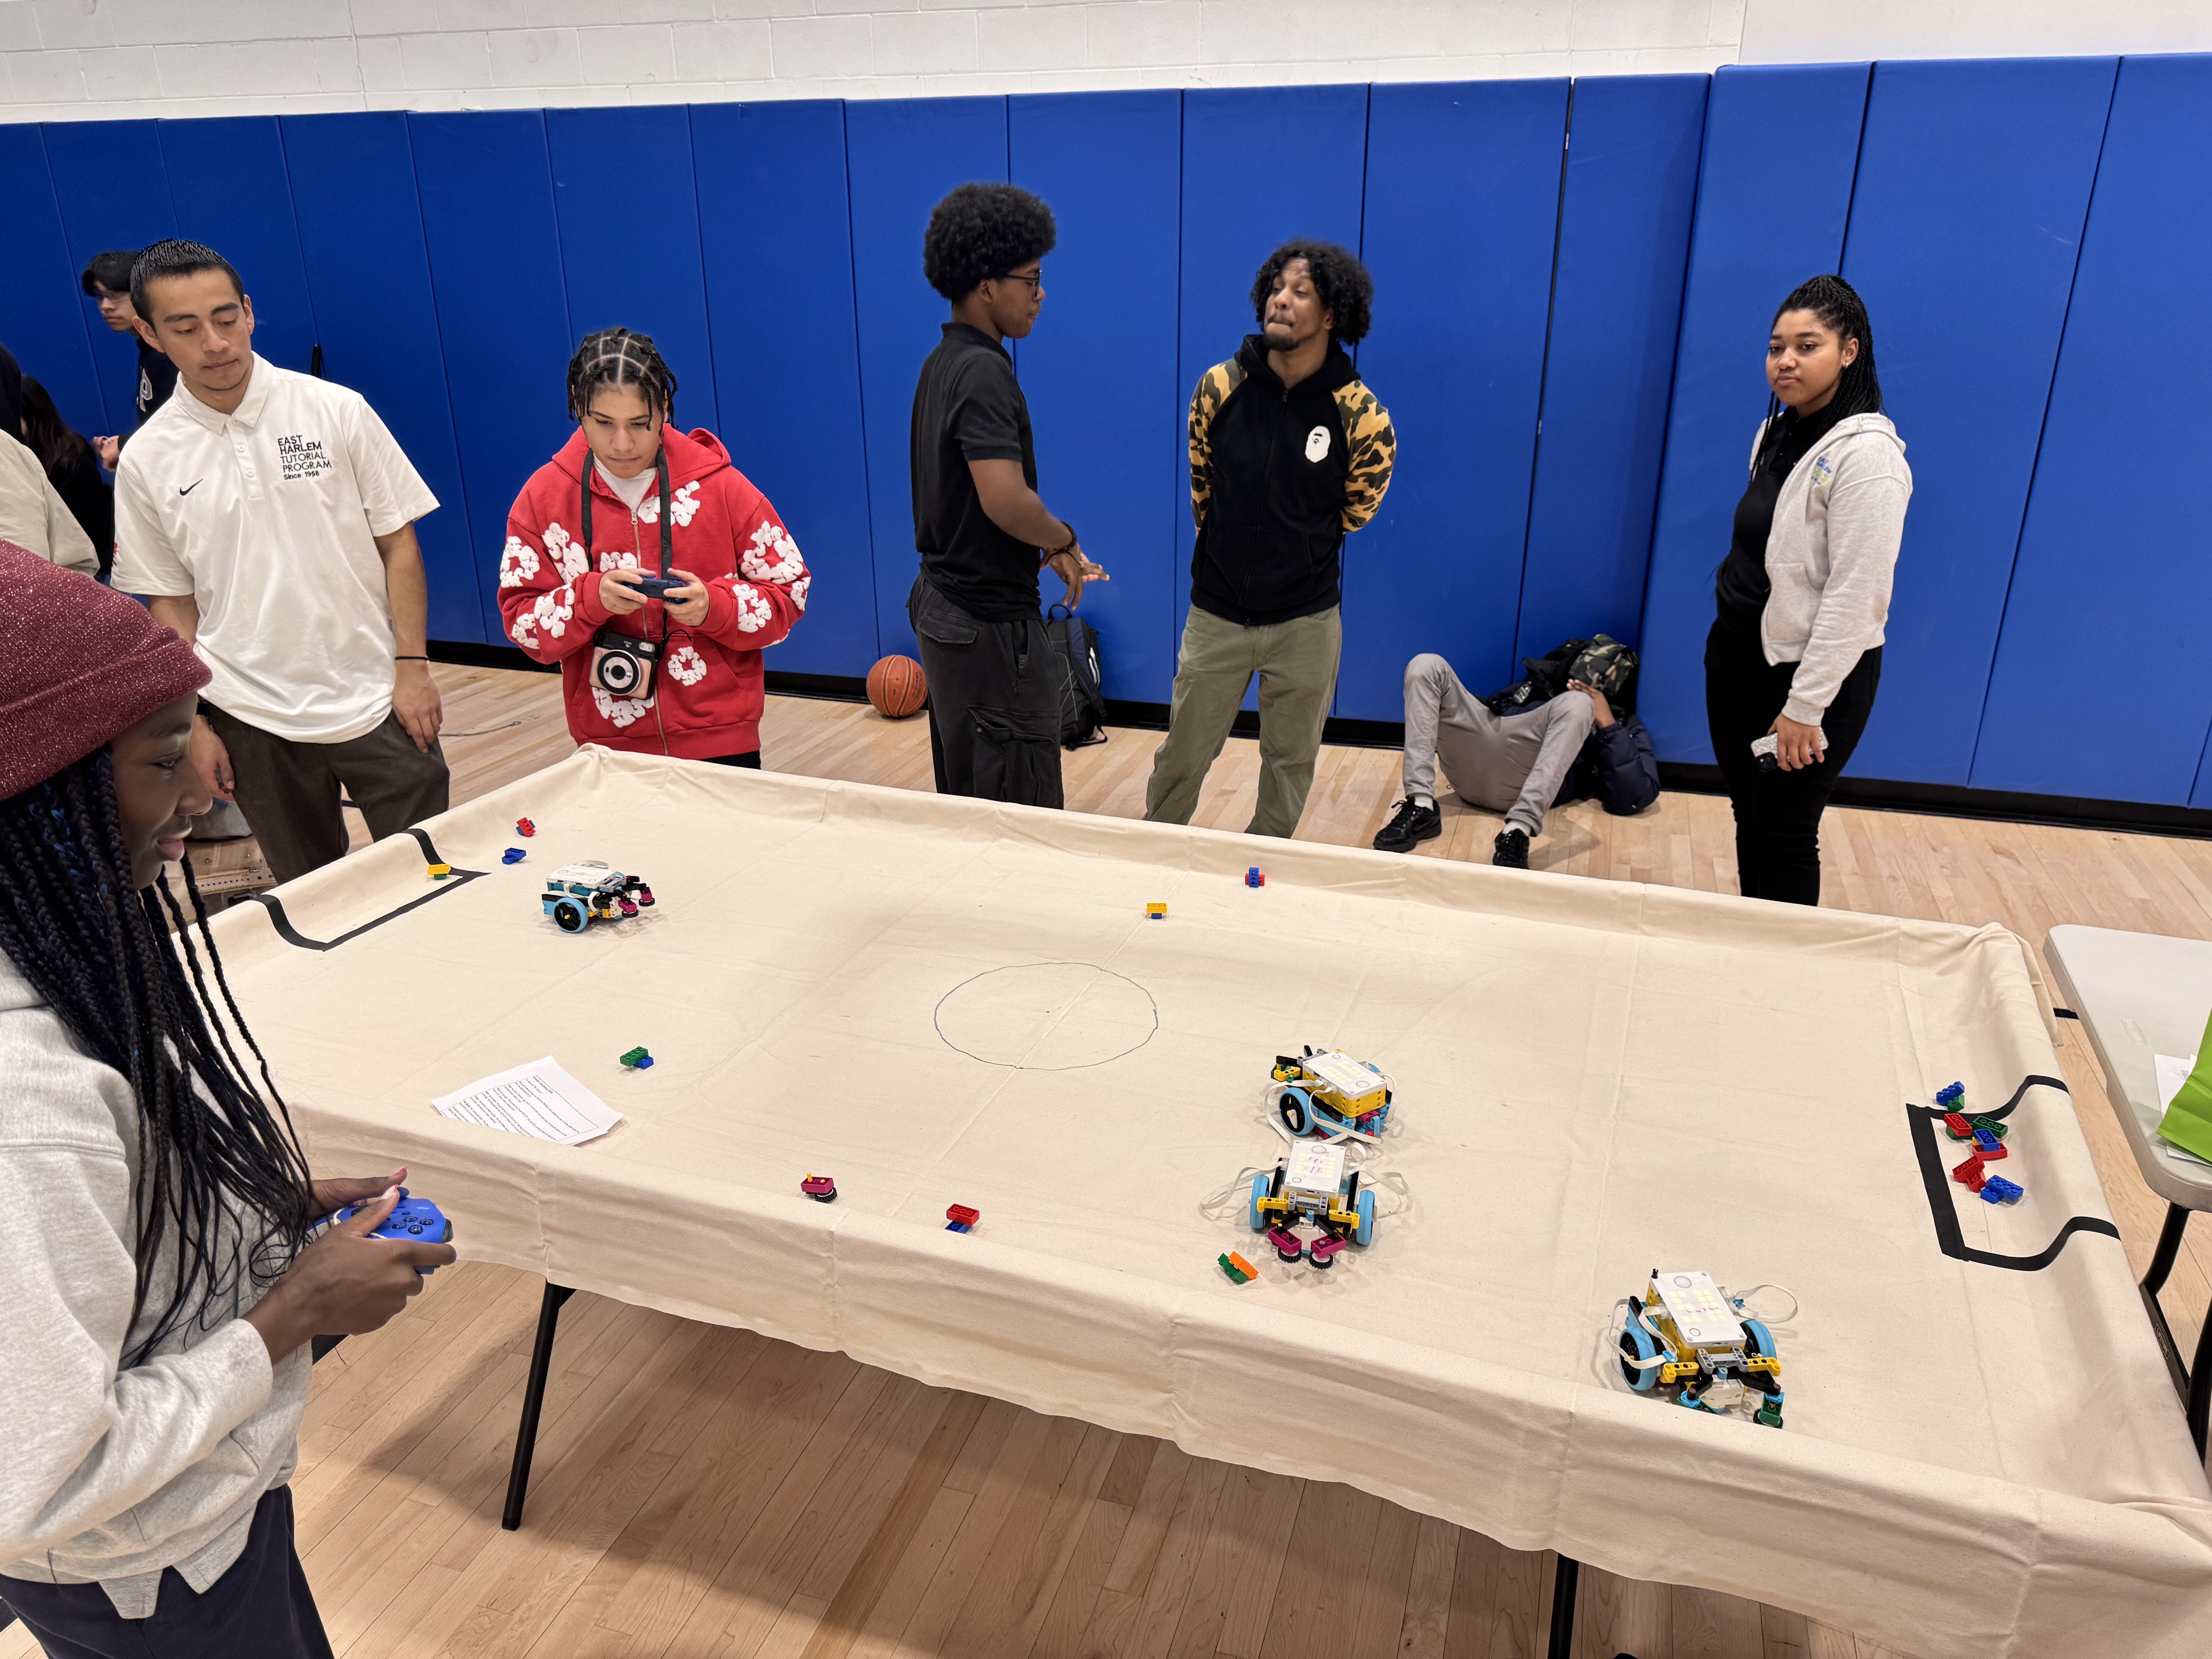
After adding the gripper, one of the scholars suggested turning it into a game. I showed them how to set up the controllers, then stepped back and let them figure out the rules and the setup themselves. They owned it from there.
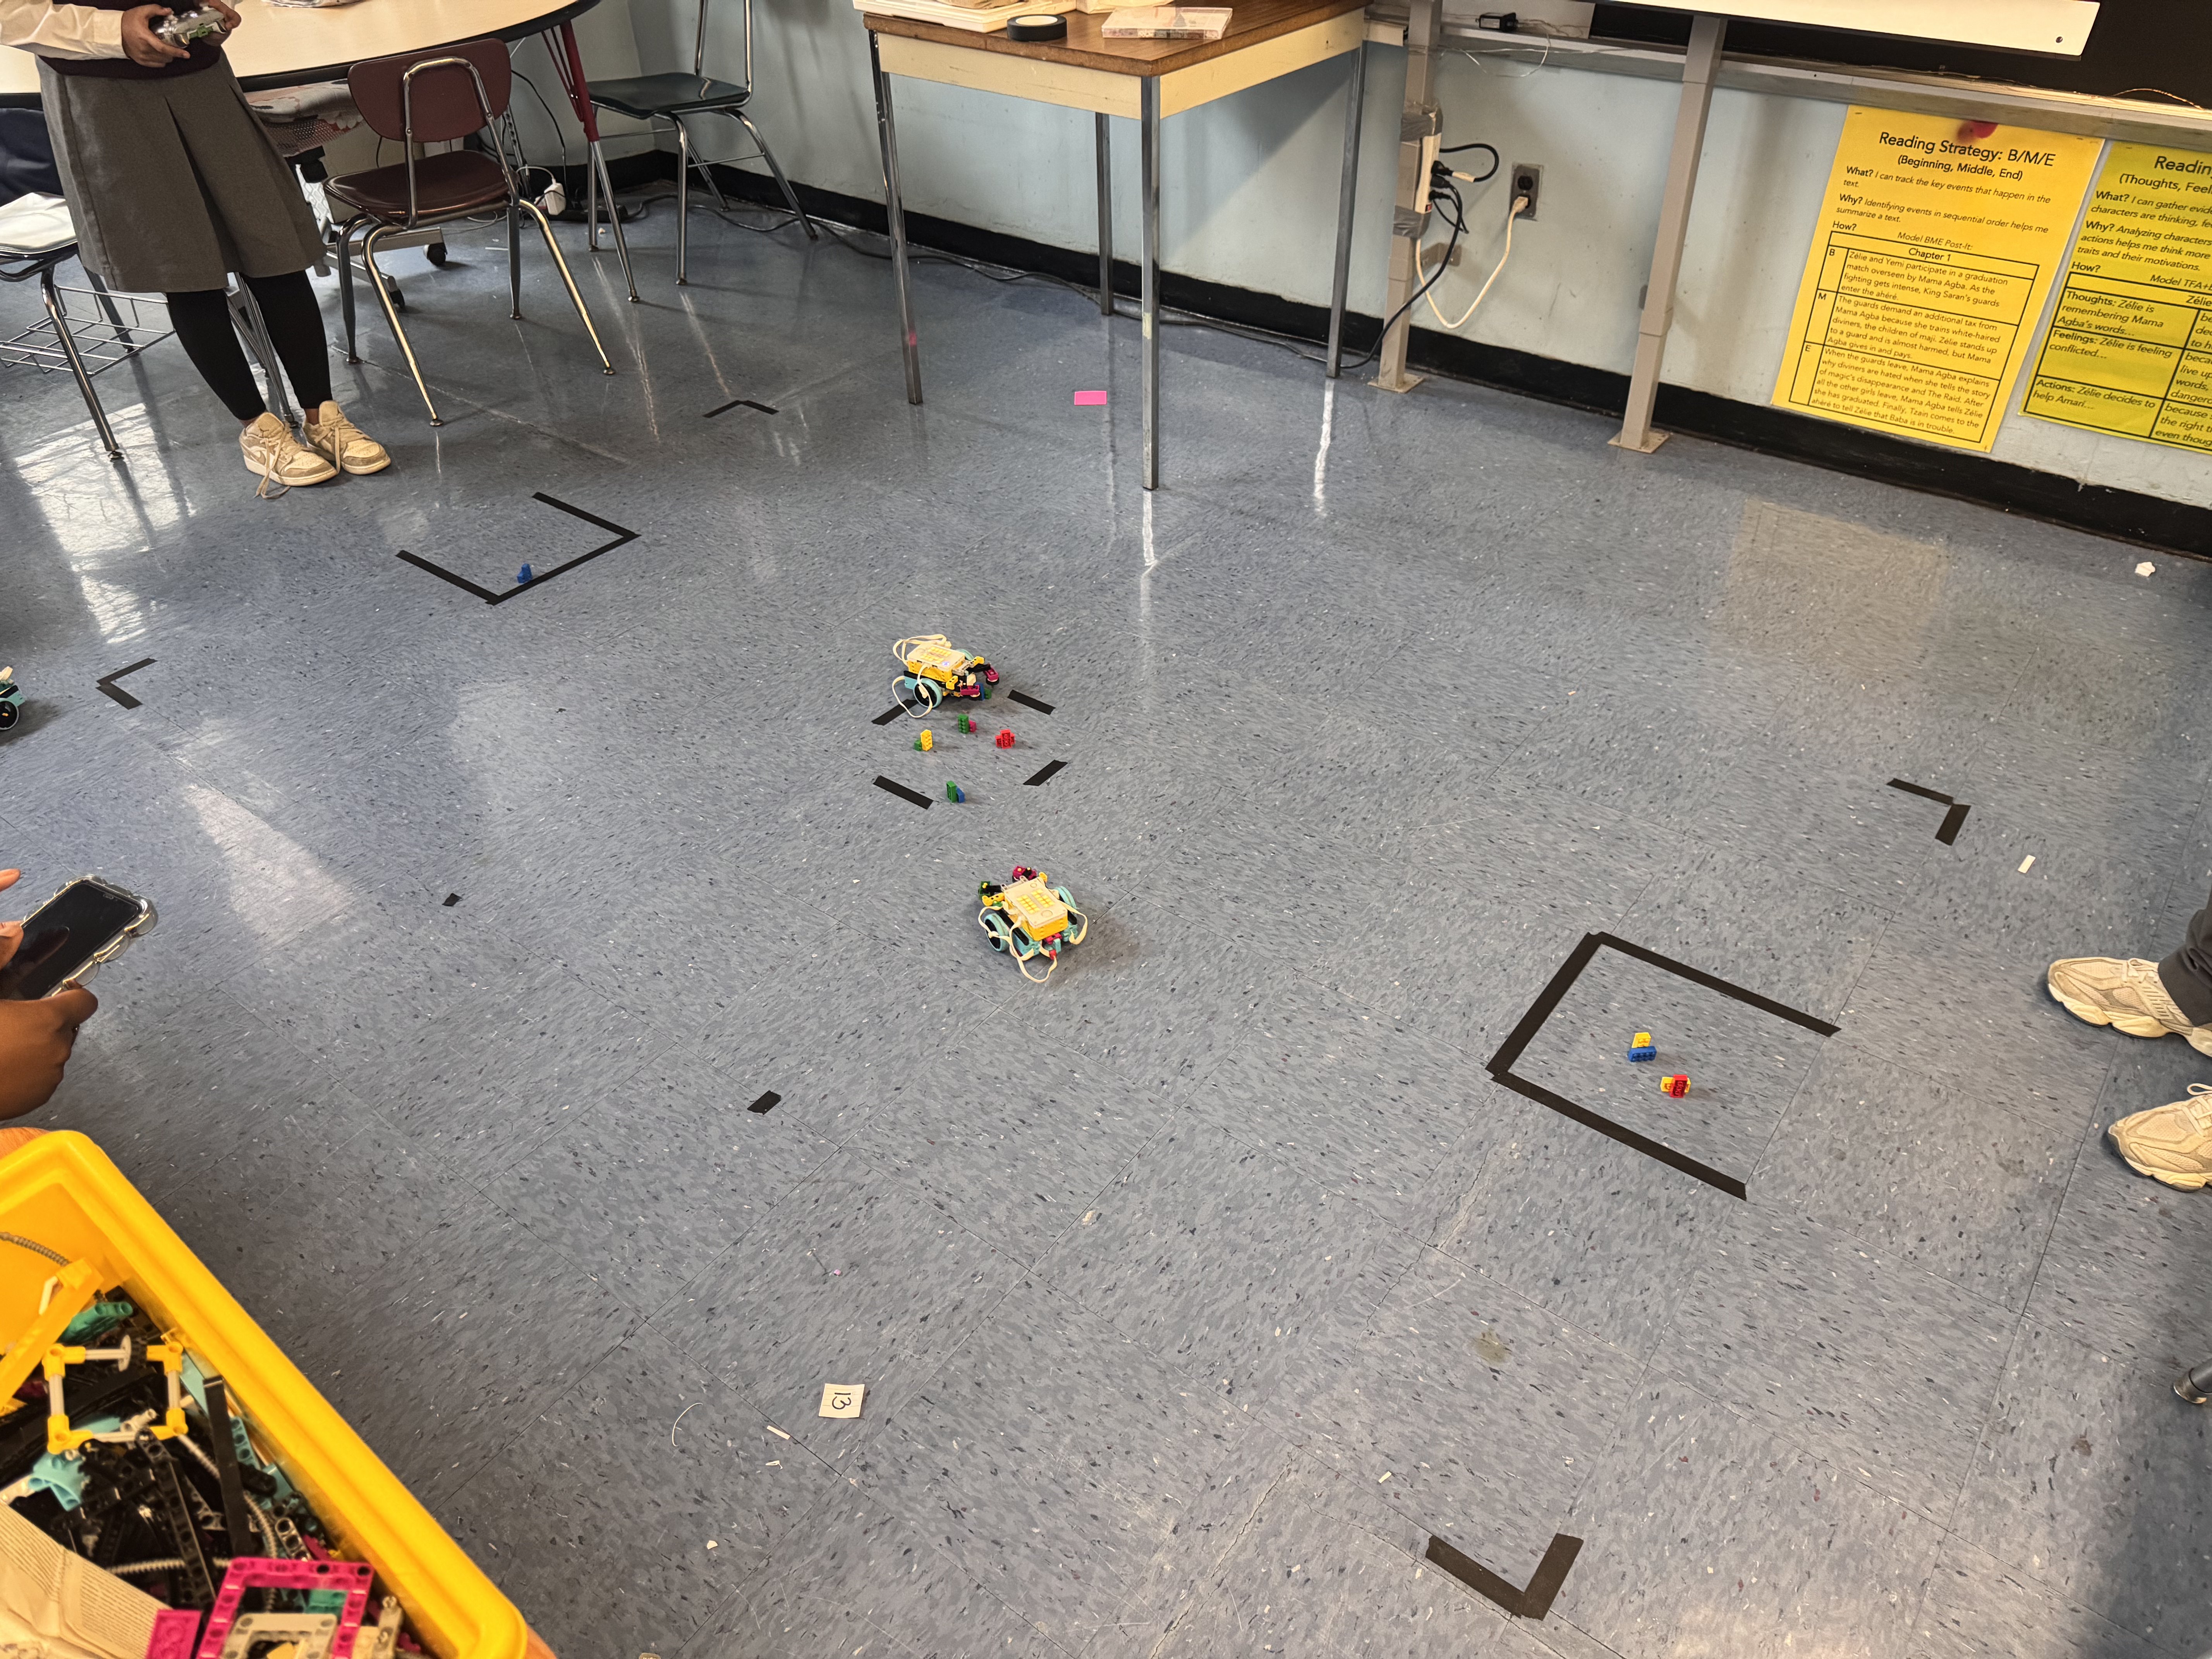
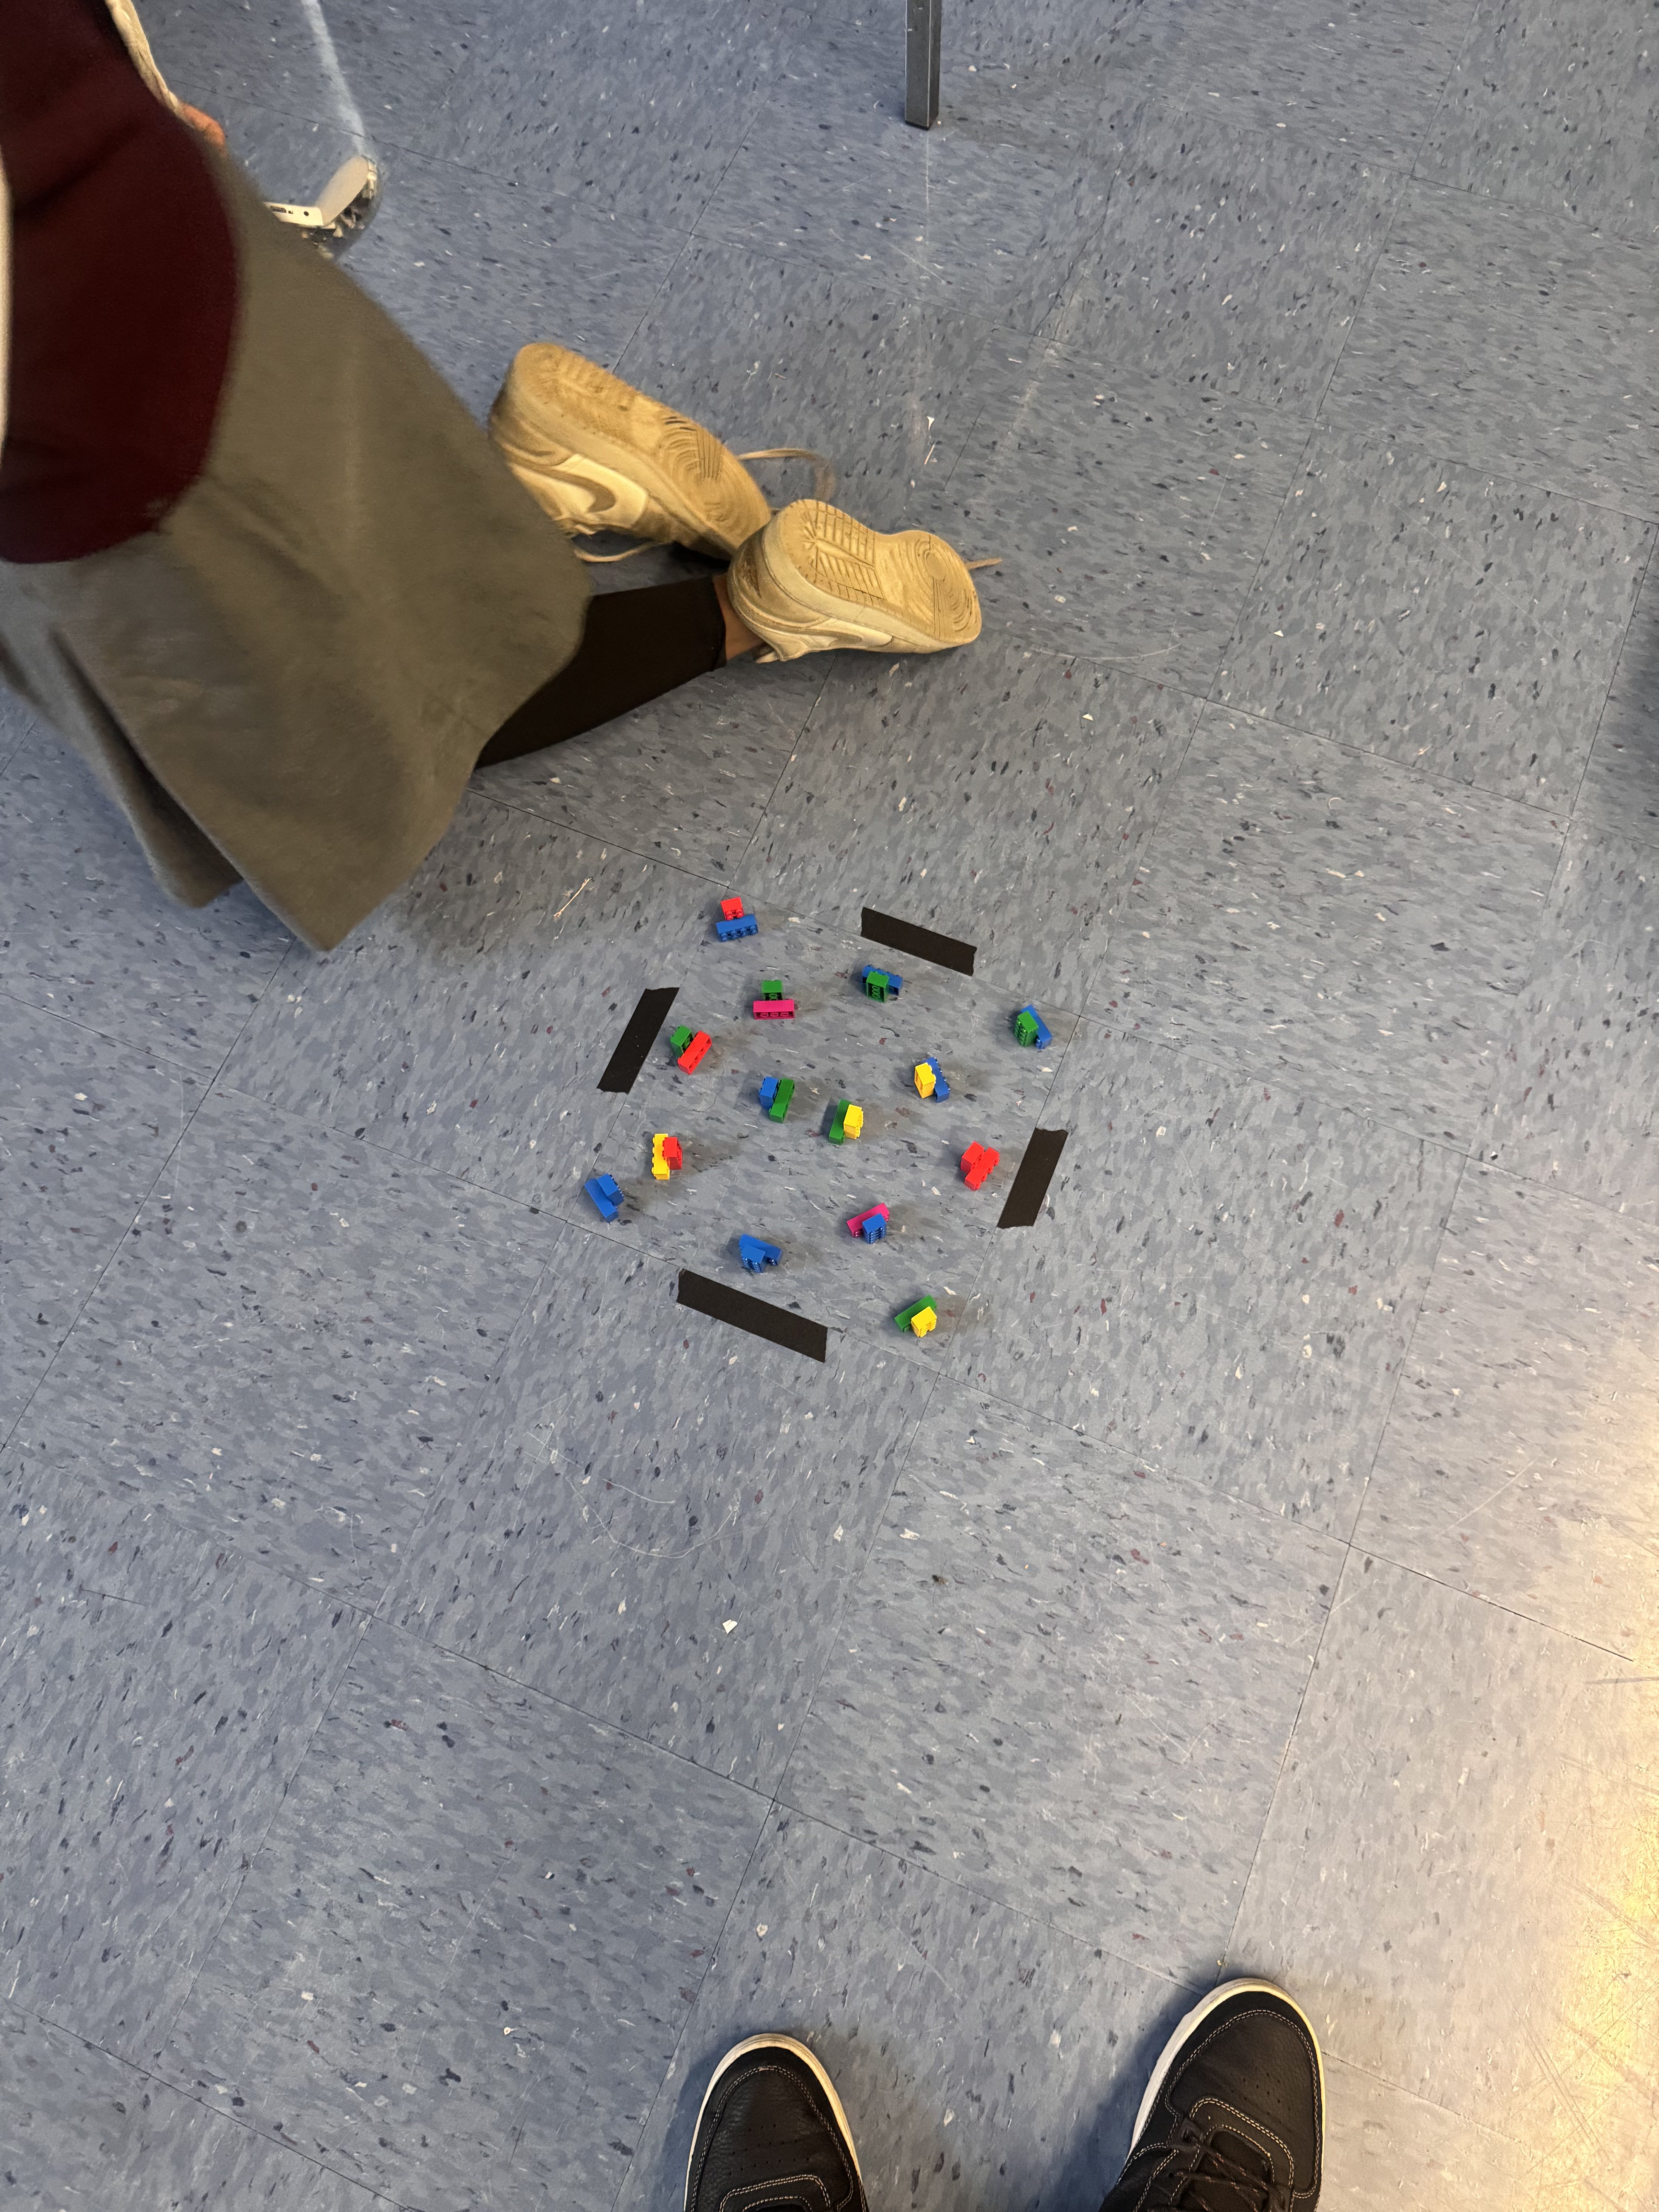
Scholars setting up the game
Testing the drive base with gripper
Scholars trying out the game
Drawing with the robot
Staff, parents, and scholars from other schools came to see the game and robot built by the Robotics scholars.
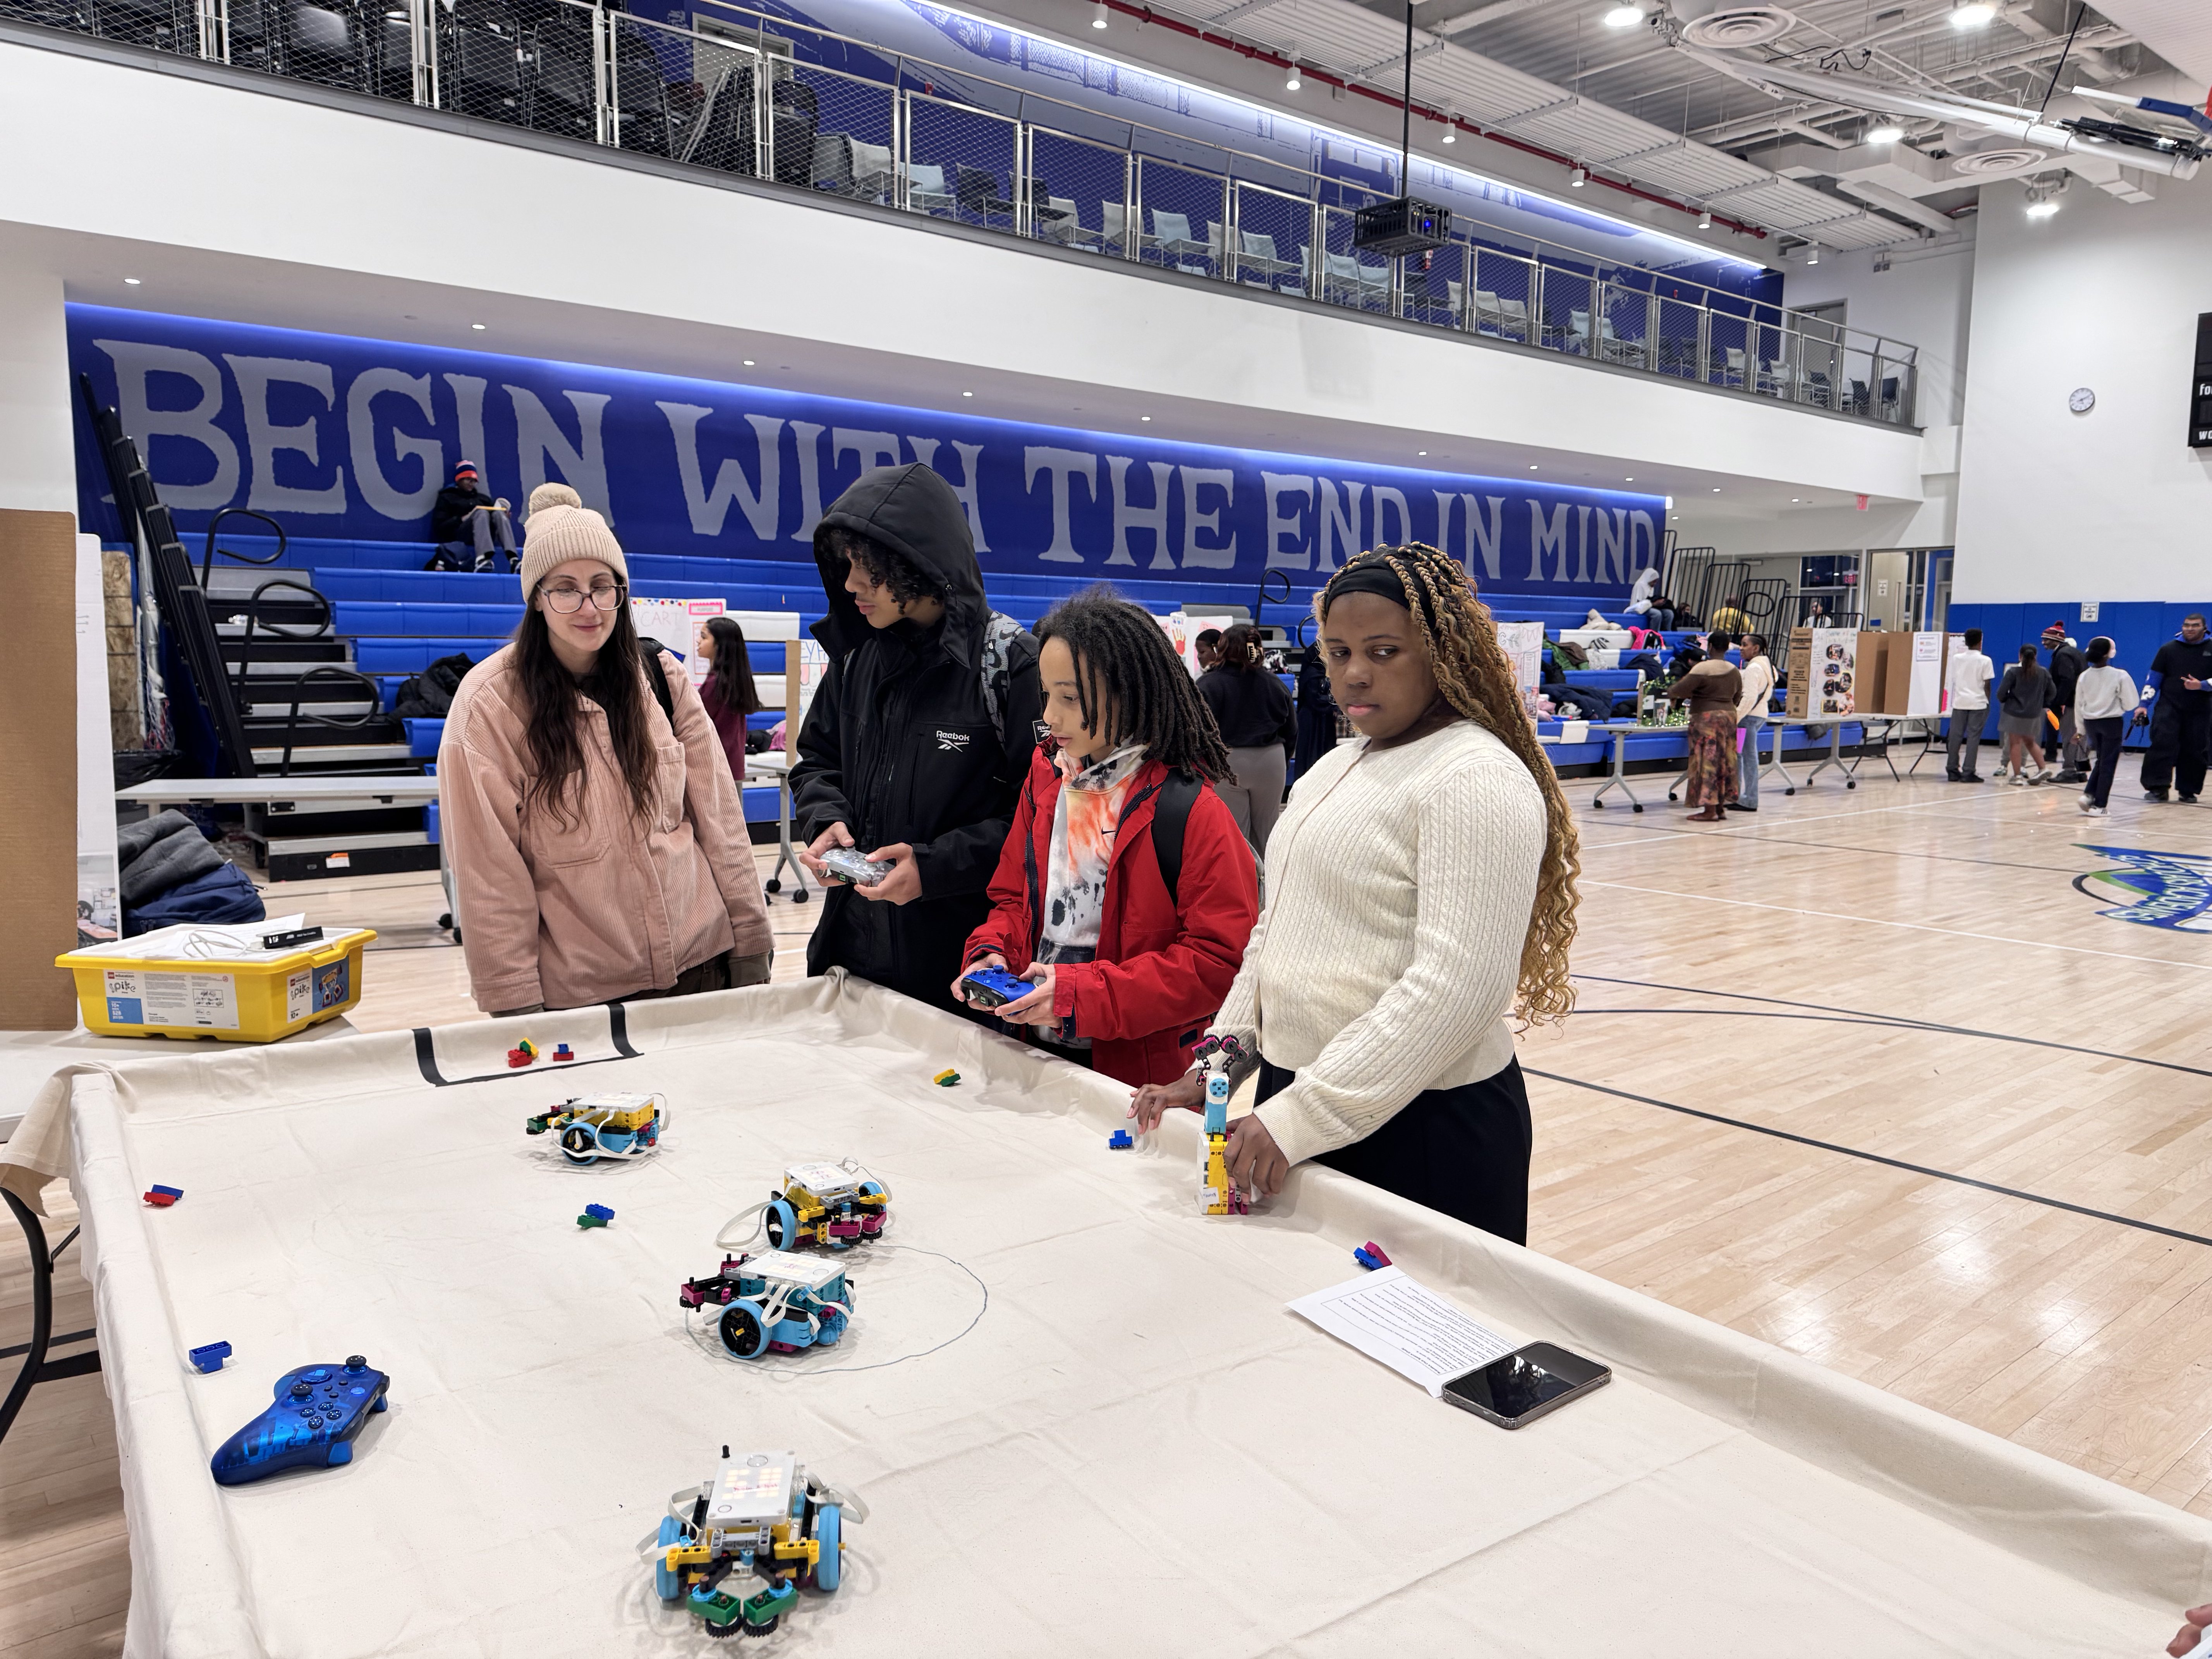
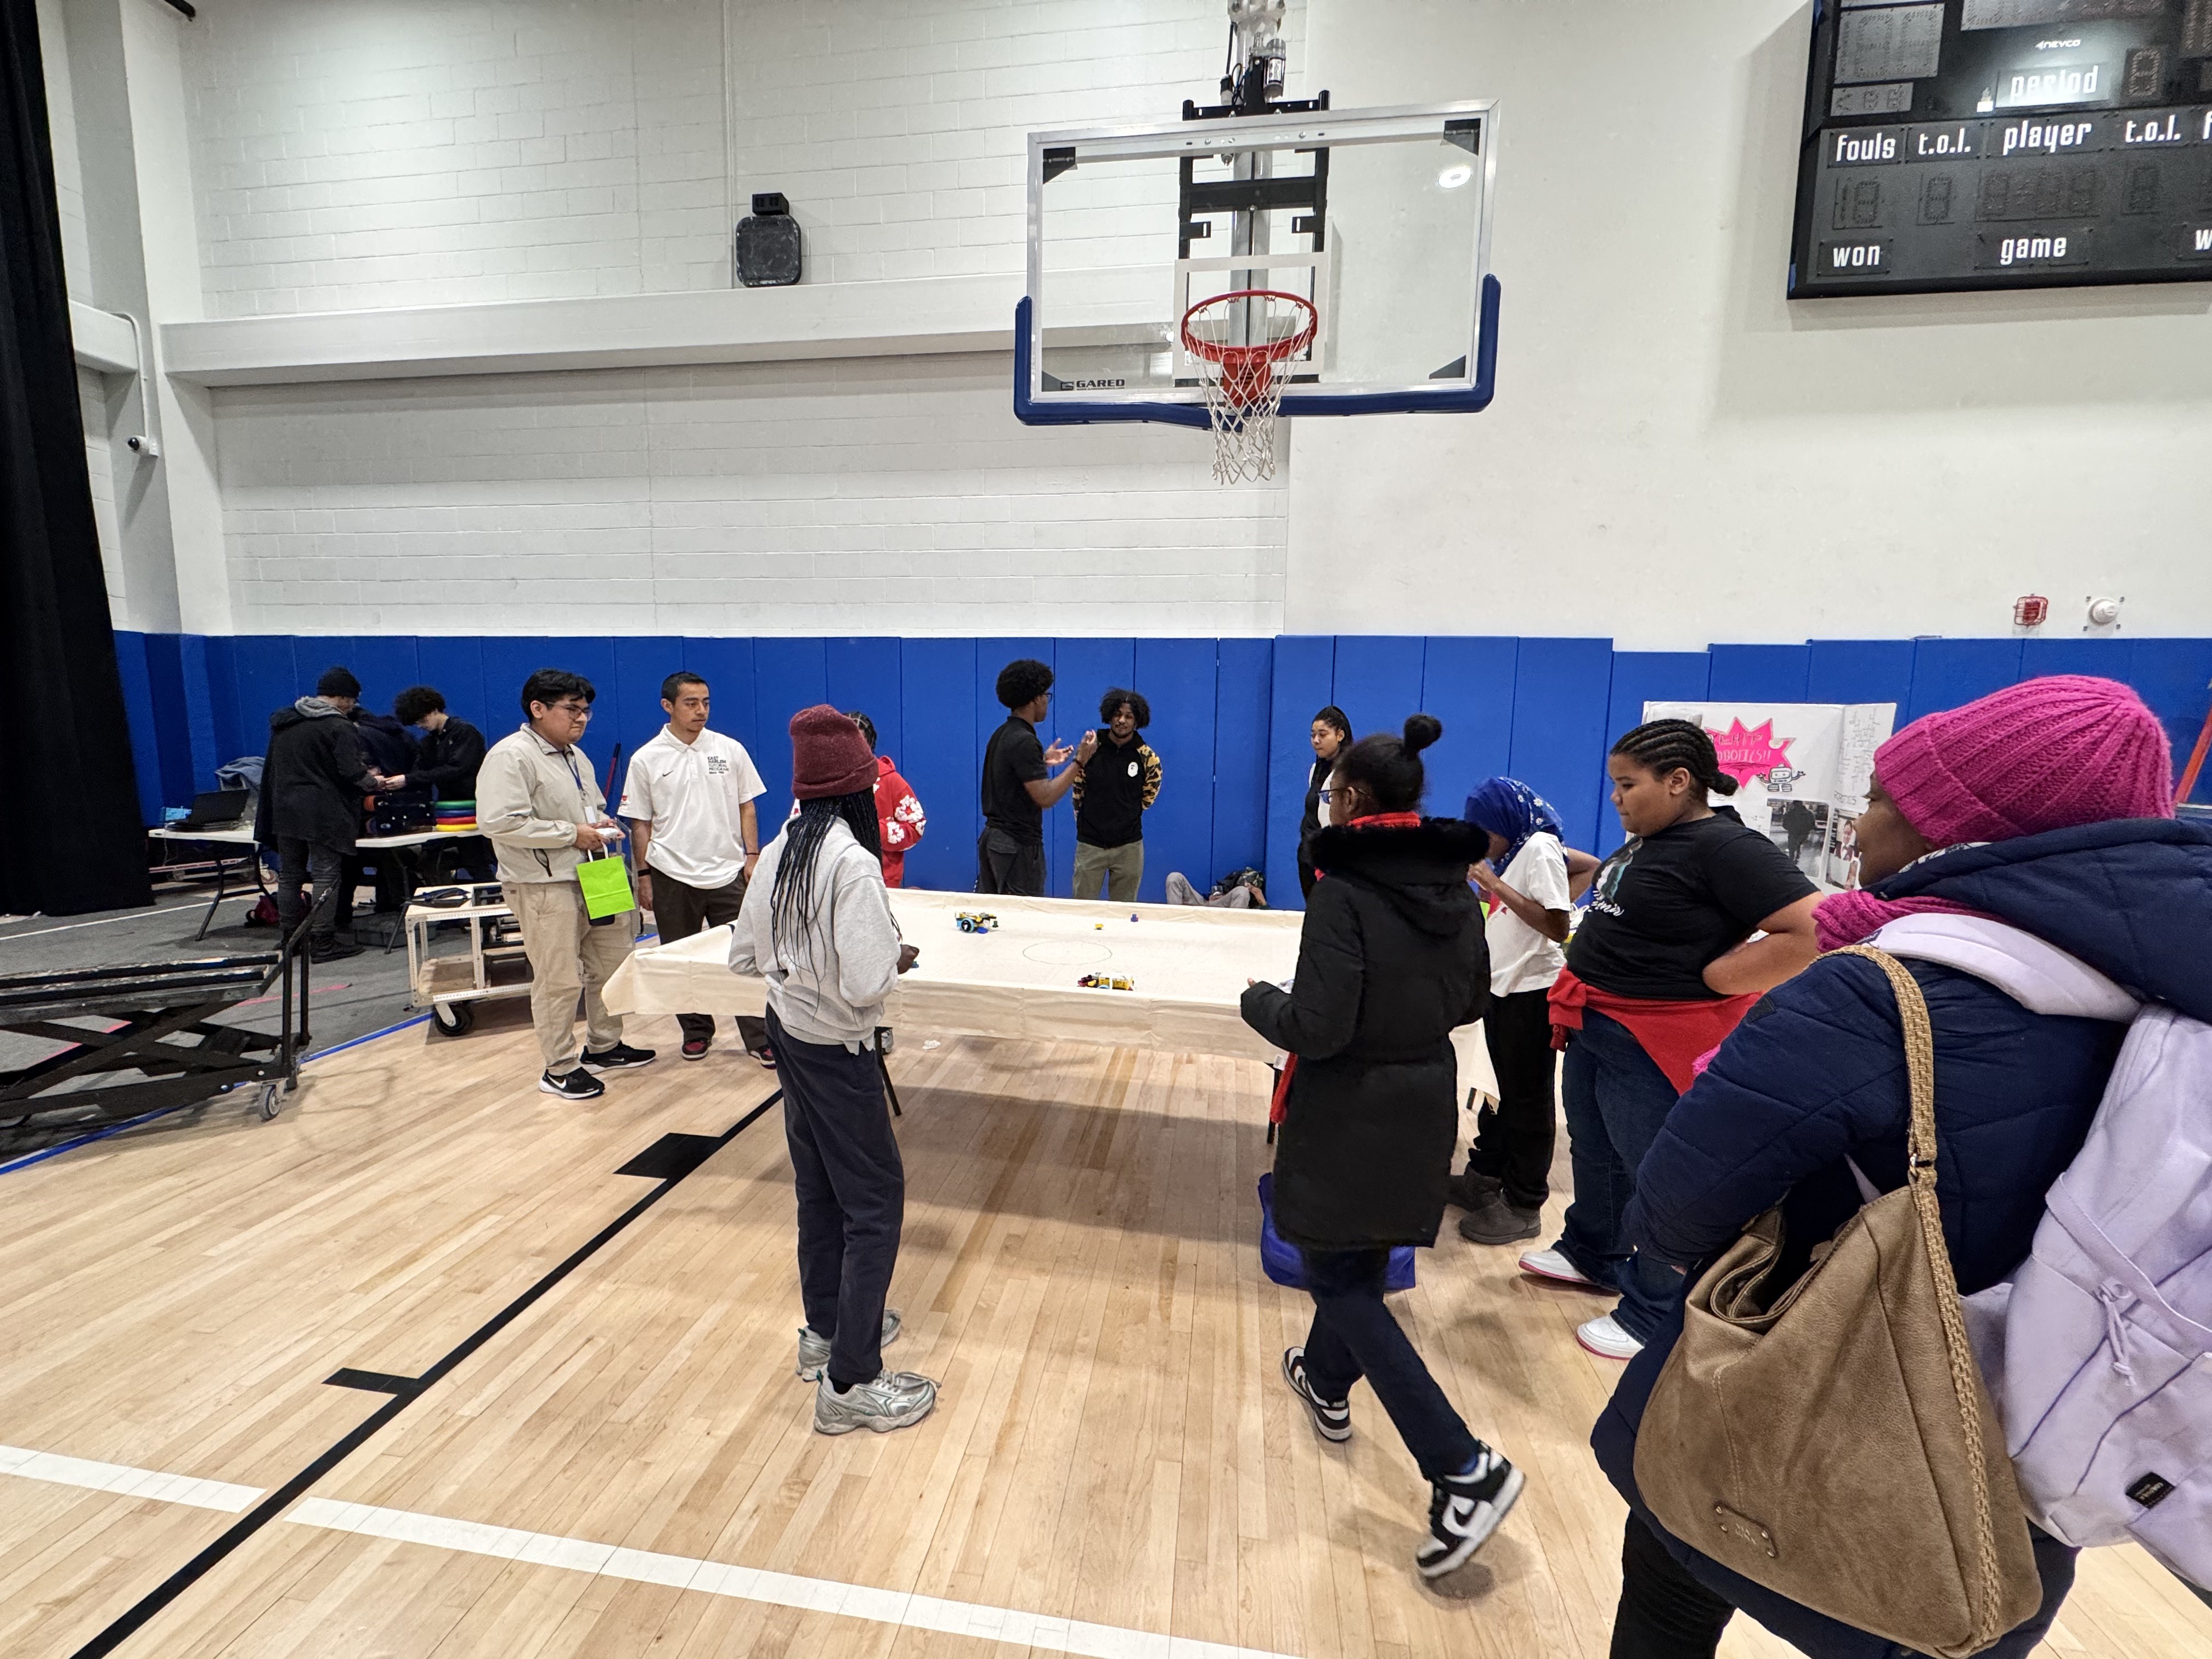
Visitors engaging with the project at the showcase